Ongoing
World models from drone trajectories
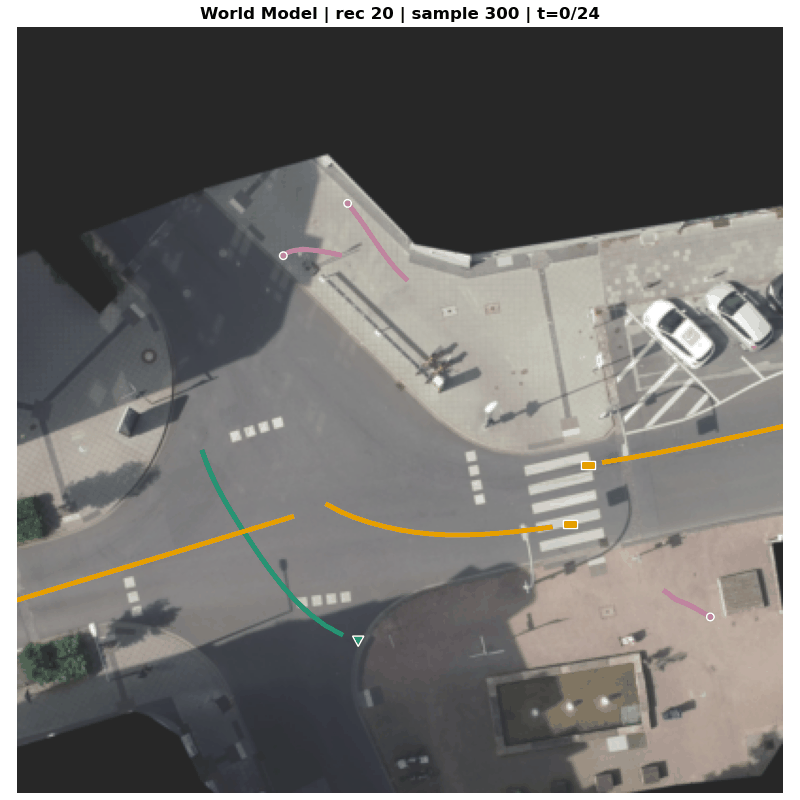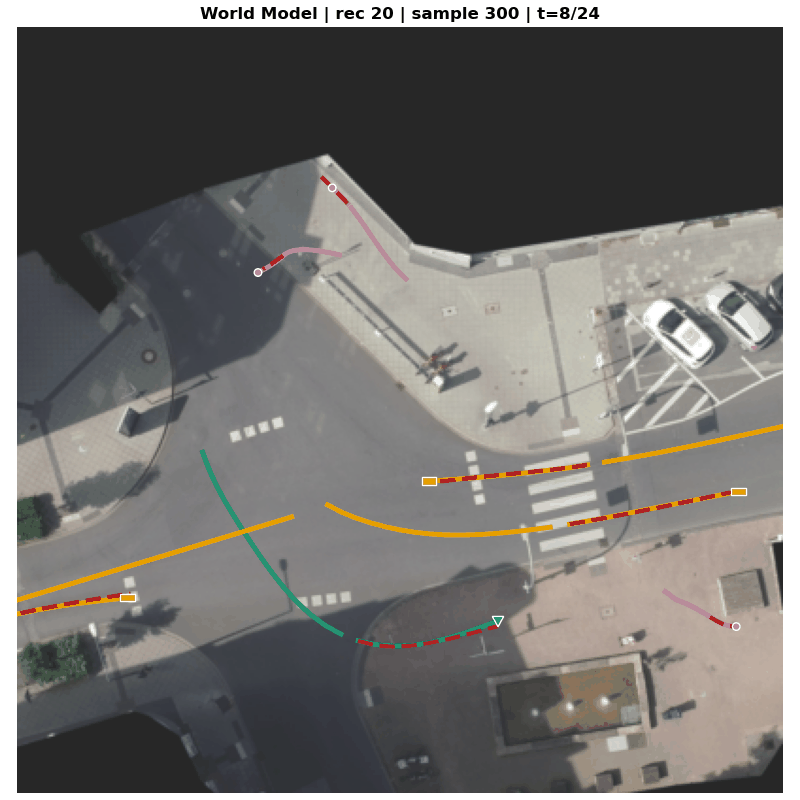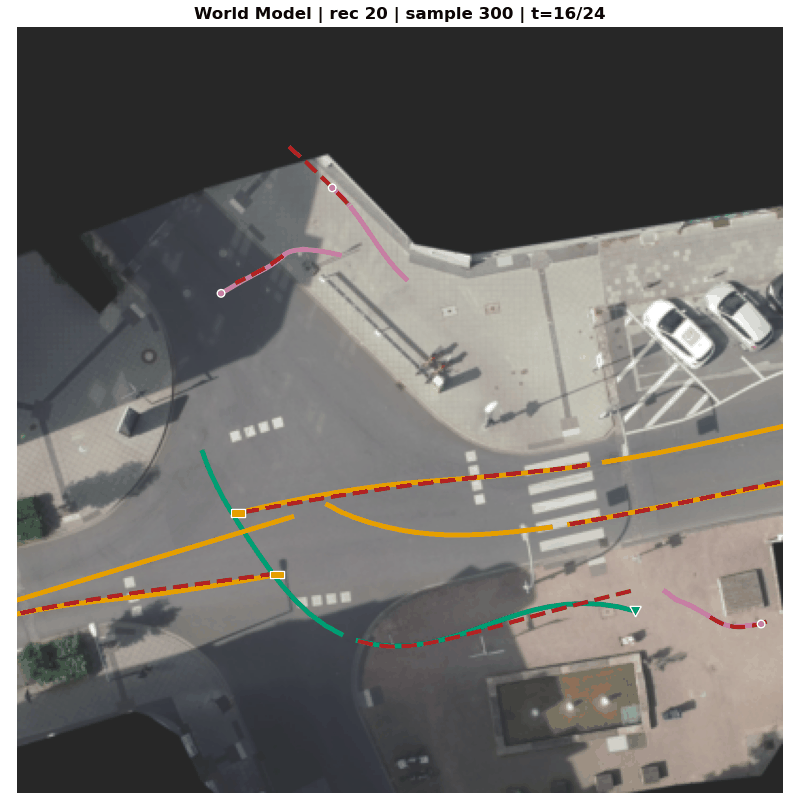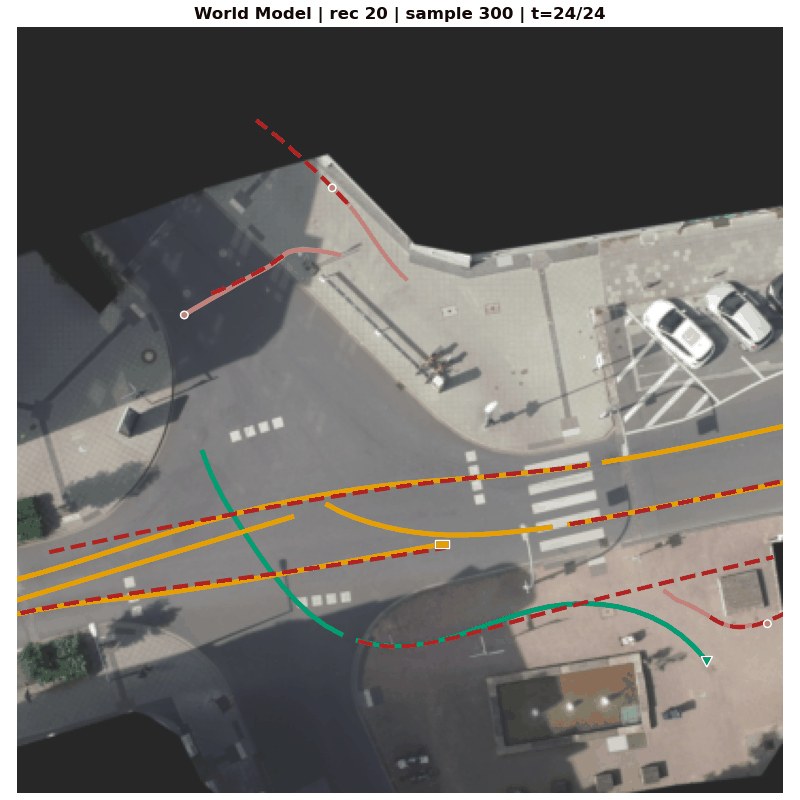
Learning interaction-aware, multimodal traffic dynamics from overhead observations of vehicles, cyclists, and pedestrians.
Project details →World models for traffic, beyond a single vehicle.
Traffic world models · Multi-agent learning · Safety
I am a PhD Candidate at the Cho Chun Shik Graduate School of Mobility, KAIST, advised by Prof. Tiantian Chen, in the Human Factors Centered Transport Safety Laboratory.
My research asks how world models can serve transportation beyond the control of a single autonomous vehicle. I use drone-recorded trajectories to study the interactions of road users across an entire traffic site, with the aim of supporting traffic understanding, prospective safety assessment, and the evaluation of digital twins.
This direction grew from my work on traffic conflicts, anomaly detection, and extreme value theory. I wanted to move from measuring an interaction after it happened to understanding how it might unfold. That led to a question I keep returning to: when does a good trajectory predictor become a useful world model? My current studies test observation dependence, closed-loop error propagation, and whether better forecasts lead to better decisions.
Previously, I completed my master’s studies at Southeast University (2020–2023), advised by Prof. Zhiyuan Liu, and my bachelor’s studies at Southwest Jiaotong University (2016–2020), in Mao Yisheng Honors College.
This site brings together my published work, manuscripts under review, and ongoing research. Read the research story or view current manuscripts.
Research portfolio
Ongoing
Learning interaction-aware, multimodal traffic dynamics from overhead observations of vehicles, cyclists, and pedestrians.
Project details →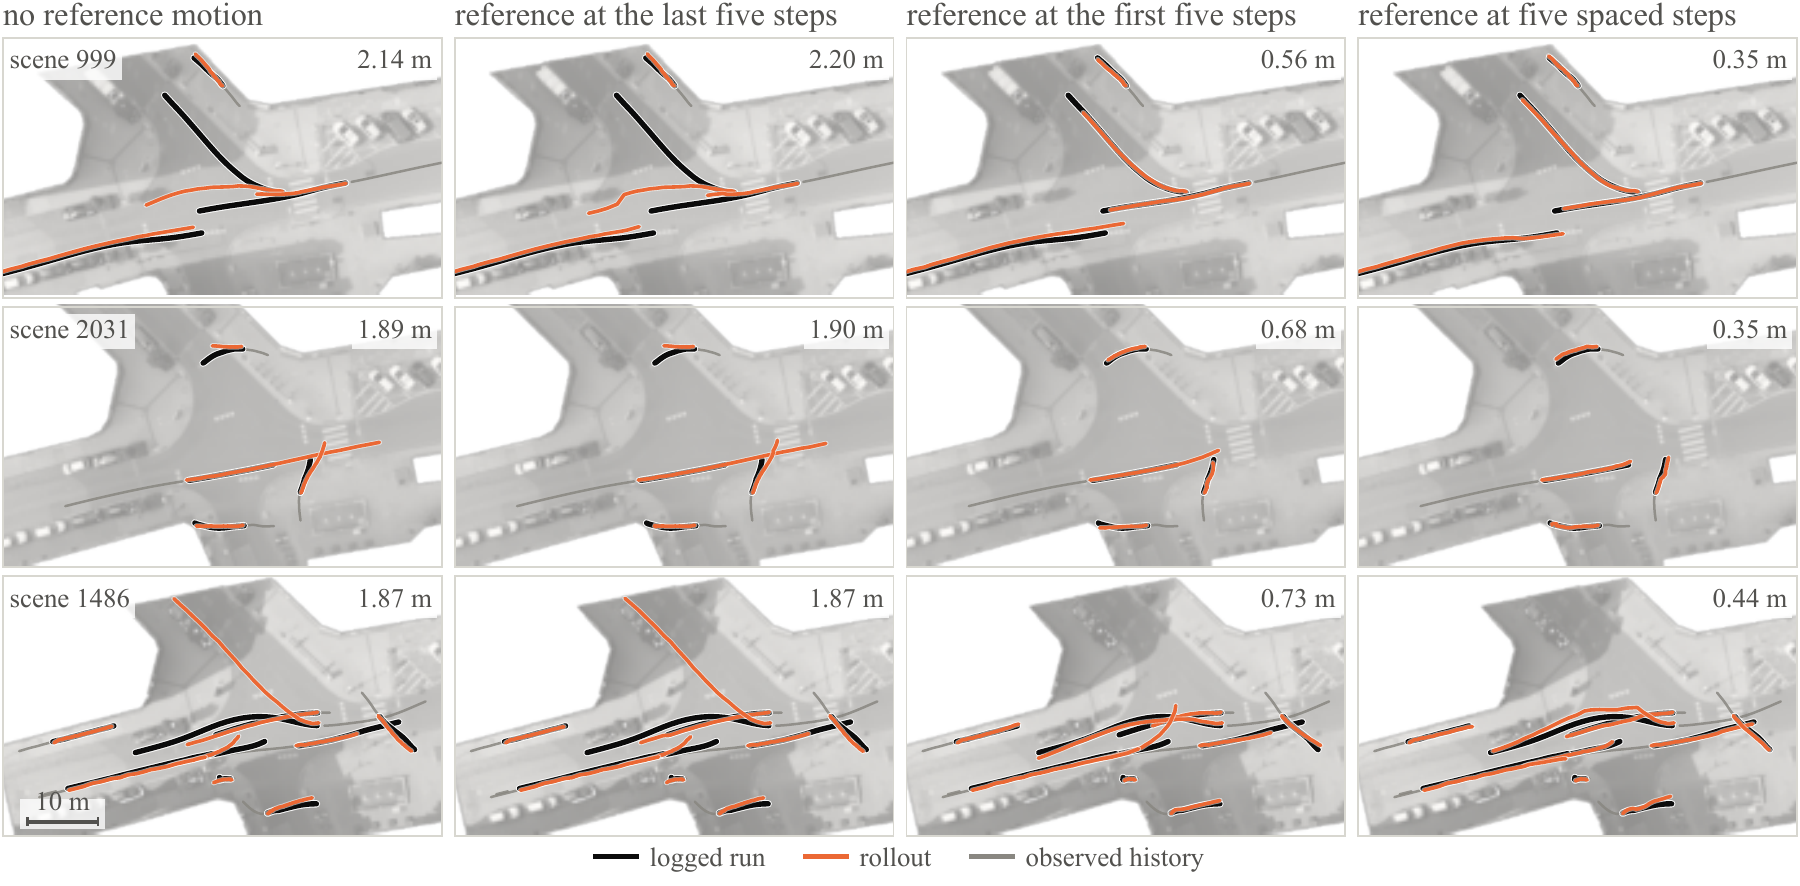
Under review · AAAI 2027
Separating action-source shift, interaction-graph changes, and the timing of error accumulation in multi-agent forecasting.
Project details →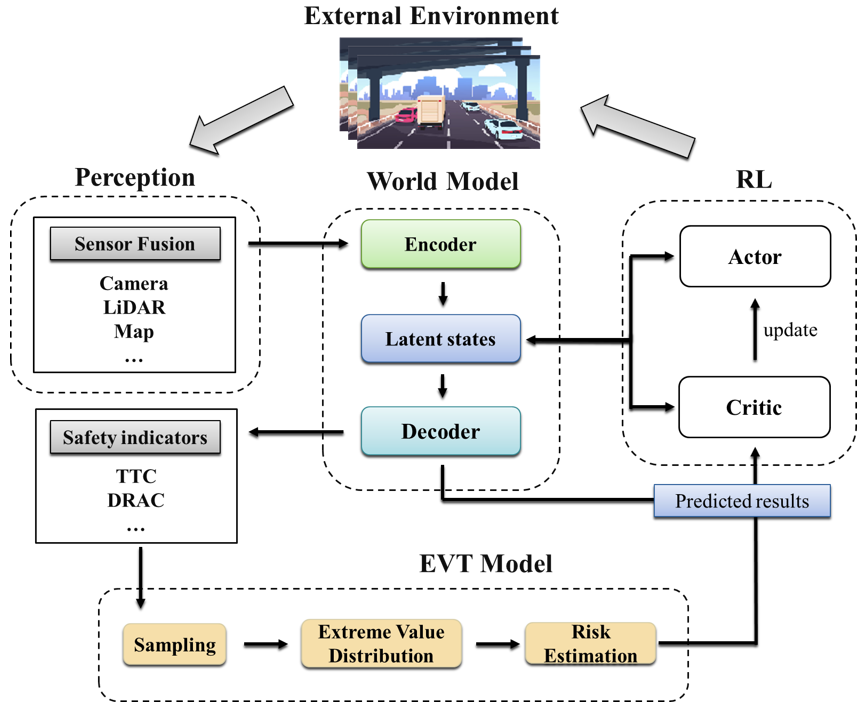
Under review · IEEE T-ITS · Earlier conference work: TRB 2025
Connecting imagined traffic outcomes, surrogate safety measures, and extreme value theory for risk-aware driving research.
Project details →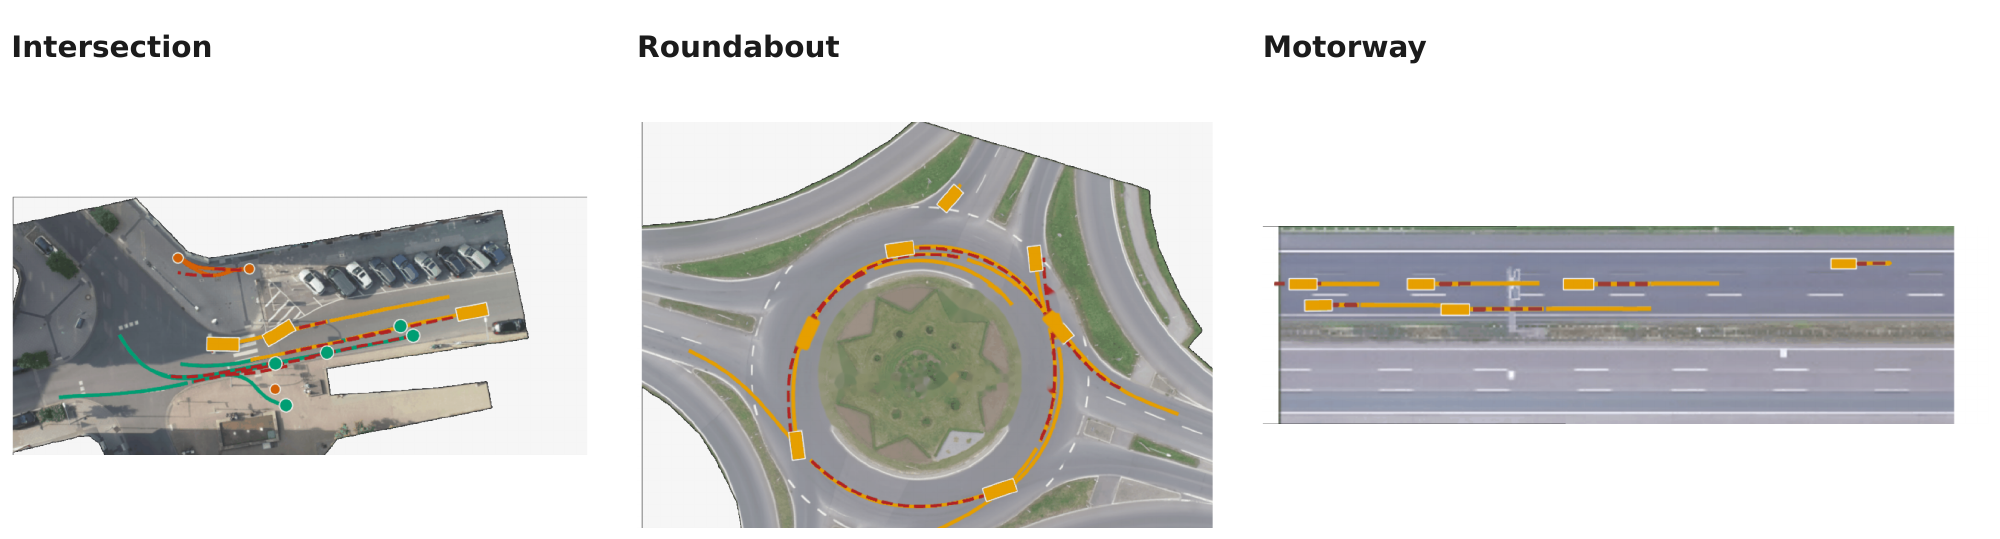
Ongoing
Examining how trajectory prediction errors and information boundaries affect traffic-conflict and tail-risk diagnostics.
Project details →